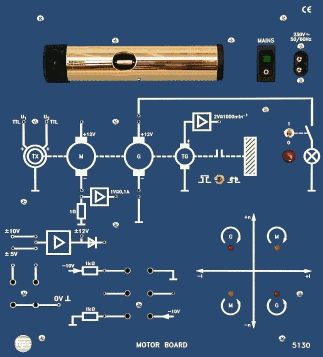
Type 5131
SERVO BOARD Type 5131
The SERVO BOARD Type 5131 is a universal positioning control system with analog angle acquisition. A switchable disturbance variable, digital speed and direction sensing, and plug-in reflective sensors make it well suited for position and servo control experiments.
- Universal positioning control system
- Analog angle acquisition
- Switchable disturbance variable caused by gear play
- Extendable by plug-in reflective sensors for digital angle acquisition
- Digital speed and direction sensing
- Digital control inputs for both directions of rotation
Operating Principle
The SERVO BOARD Type 5131 is designed as a compact positioning control system combining analog angle acquisition with a robust mechanical servo structure.
The switchable disturbance variable in the form of gear play enables realistic control experiments under changed operating conditions.
Plug-in reflective sensors extend the system for digital angle acquisition; in addition, digital signals for speed and direction of rotation are available.
Operation and Layout
The system is intended for direct use in laboratory and training environments and provides a clearly structured front panel with the connections required for the experiments.
The board is arranged so that analog and digital measurement and control signals can be directly acquired and evaluated at the unit.
Experiment Manual and Contents
The SERVO BOARD is supplied with experiment manual V 0122 including table of contents, tasks and solutions. The manual covers the complete series of control-system, speed-control and position-control experiments and also includes an appendix.
- Mains connection
- 230 V AC / 115 V AC (110 V AC), 50 ... 60 Hz, 20 VA
- Motor
- 12 V DC, max. 0.4 A
- Encoder disk
- 125 min-1, 24 lines / rev. / 15°, 48 lines / rev. / 7.5°
- DC amplifier
- Input 0 ... +/-10 V, gain V = 1.2, output current max. 0.5 A
- Motor control logic
- TTL level; logic 1 = clockwise / counterclockwise rotation
- Resistor
- 5 kOhm (+/-20%)
- Mechanical rotation range
- 320° (+/-1.5%), without stop
- Linearity tolerance
- 2%
- Actual-value output
- 0 ... 10 V
- Outputs U1/U2
- TTL, 90° phase-shifted relative to each other
- Dimensions/weight
- 266 x 297 x 110 mm (W x H x D) / approx. 2.1 kg
- Sensor sockets
- 2 sockets for reflective sensors
- Adapter fields
- 4 mm and 2 mm adapter fields
- Scope of delivery
- Reflective sensors
- 1 Parameters of the Speed Controlled System3
- 2 Parameters of the Temperature and Light Controlled System17
- 3 The Motor with Current and Torque Control25
- 4 Speed Control37
- 5 Voltage Control with a Machine Generator47
- 6 Speed Control with Cascade Current Control55
- 7 DC Motor on the Uncontrolled and Controlled Single-phase, Half-wave Rectifier75
- 8 Four Quadrant Operation of a DC Motor with a Thyristor Static Converter87
- 9 Four Quadrant Operation with an H-bridge103
- 10 Electronic Load119
- 11 Temperature Control with P and PI Controller125
- 12 Temperature Control with a Two-step Controller135
- 13 Temperature Control with PID Controller and Pulse Group Control143
- 14 Brightness Control with P, PI and PID Controller149
- 15 Bode Diagram, Locus and Controllability of a P-T3 System155
- 16 Matching and Smoothing of Actual Values173
- 17 Parameters and Operating Behaviour of the Servo Controlled System183
- 18 Positioning Action189
- 19 Positioning Action with Influencing Variables197
Taken from the tables of contents of the hps experiment manuals (titles, numbers and pages). All manuals are German; titles are shown in the original language. All manuals and experiments
V 0122 Regelstrecken-Regelkreise Manual · 333 pages 19 experiments
Main device of this manual – applies to all experiments View table of contents
- 1 Kenngrößen der Drehzahlregelstrecke p. 3
- 2 Kenngrößen der Temperatur- und Lichtregelstrecke p. 17
- 3 Der Motor mit Strom- bzw. Momentenregelung p. 25
- 4 Drehzahlregelung p. 37
- 5 Spannungsregelung mit einem Maschinengenerator p. 47
- 6 Drehzahlregelung mit unterlagerter Stromregelung p. 55
- 7 Gleichstrommotor am ungesteuerten und gesteuerten Einphasen-Einweg-Gleichrichter p. 75
- 8 Vierquadrantenbetrieb eines Gleichstrommotors mit einem Thyristor-Stromrichter p. 87
- 9 Vierquadrantenbetrieb mit einer H-Brücke p. 103
- 10 Elektronische Last p. 119
- 11 Temperaturregelung mit P- und PI-Regler p. 125
- 12 Temperaturregelung mit einem Zweipunktregler p. 135
- 13 Temperaturregelung mit PID-Regler und Impulsgruppensteuerung p. 143
- 14 Helligkeitsregelung mit P-, PI- und PID-Regler p. 149
- 15 Bode-Diagramm, Ortskurve und Regelbarkeit einer P-T3-Strecke p. 155
- 16 Anpassung und Glättung von Istwerten p. 173
- 17 Kenngrößen und Betriebsverhalten der Servo-Regelstrecke p. 183
- 18 Lageregelung p. 189
- 19 Lageregelung mit Einflußgrößen p. 197
No experiment matches the filter.